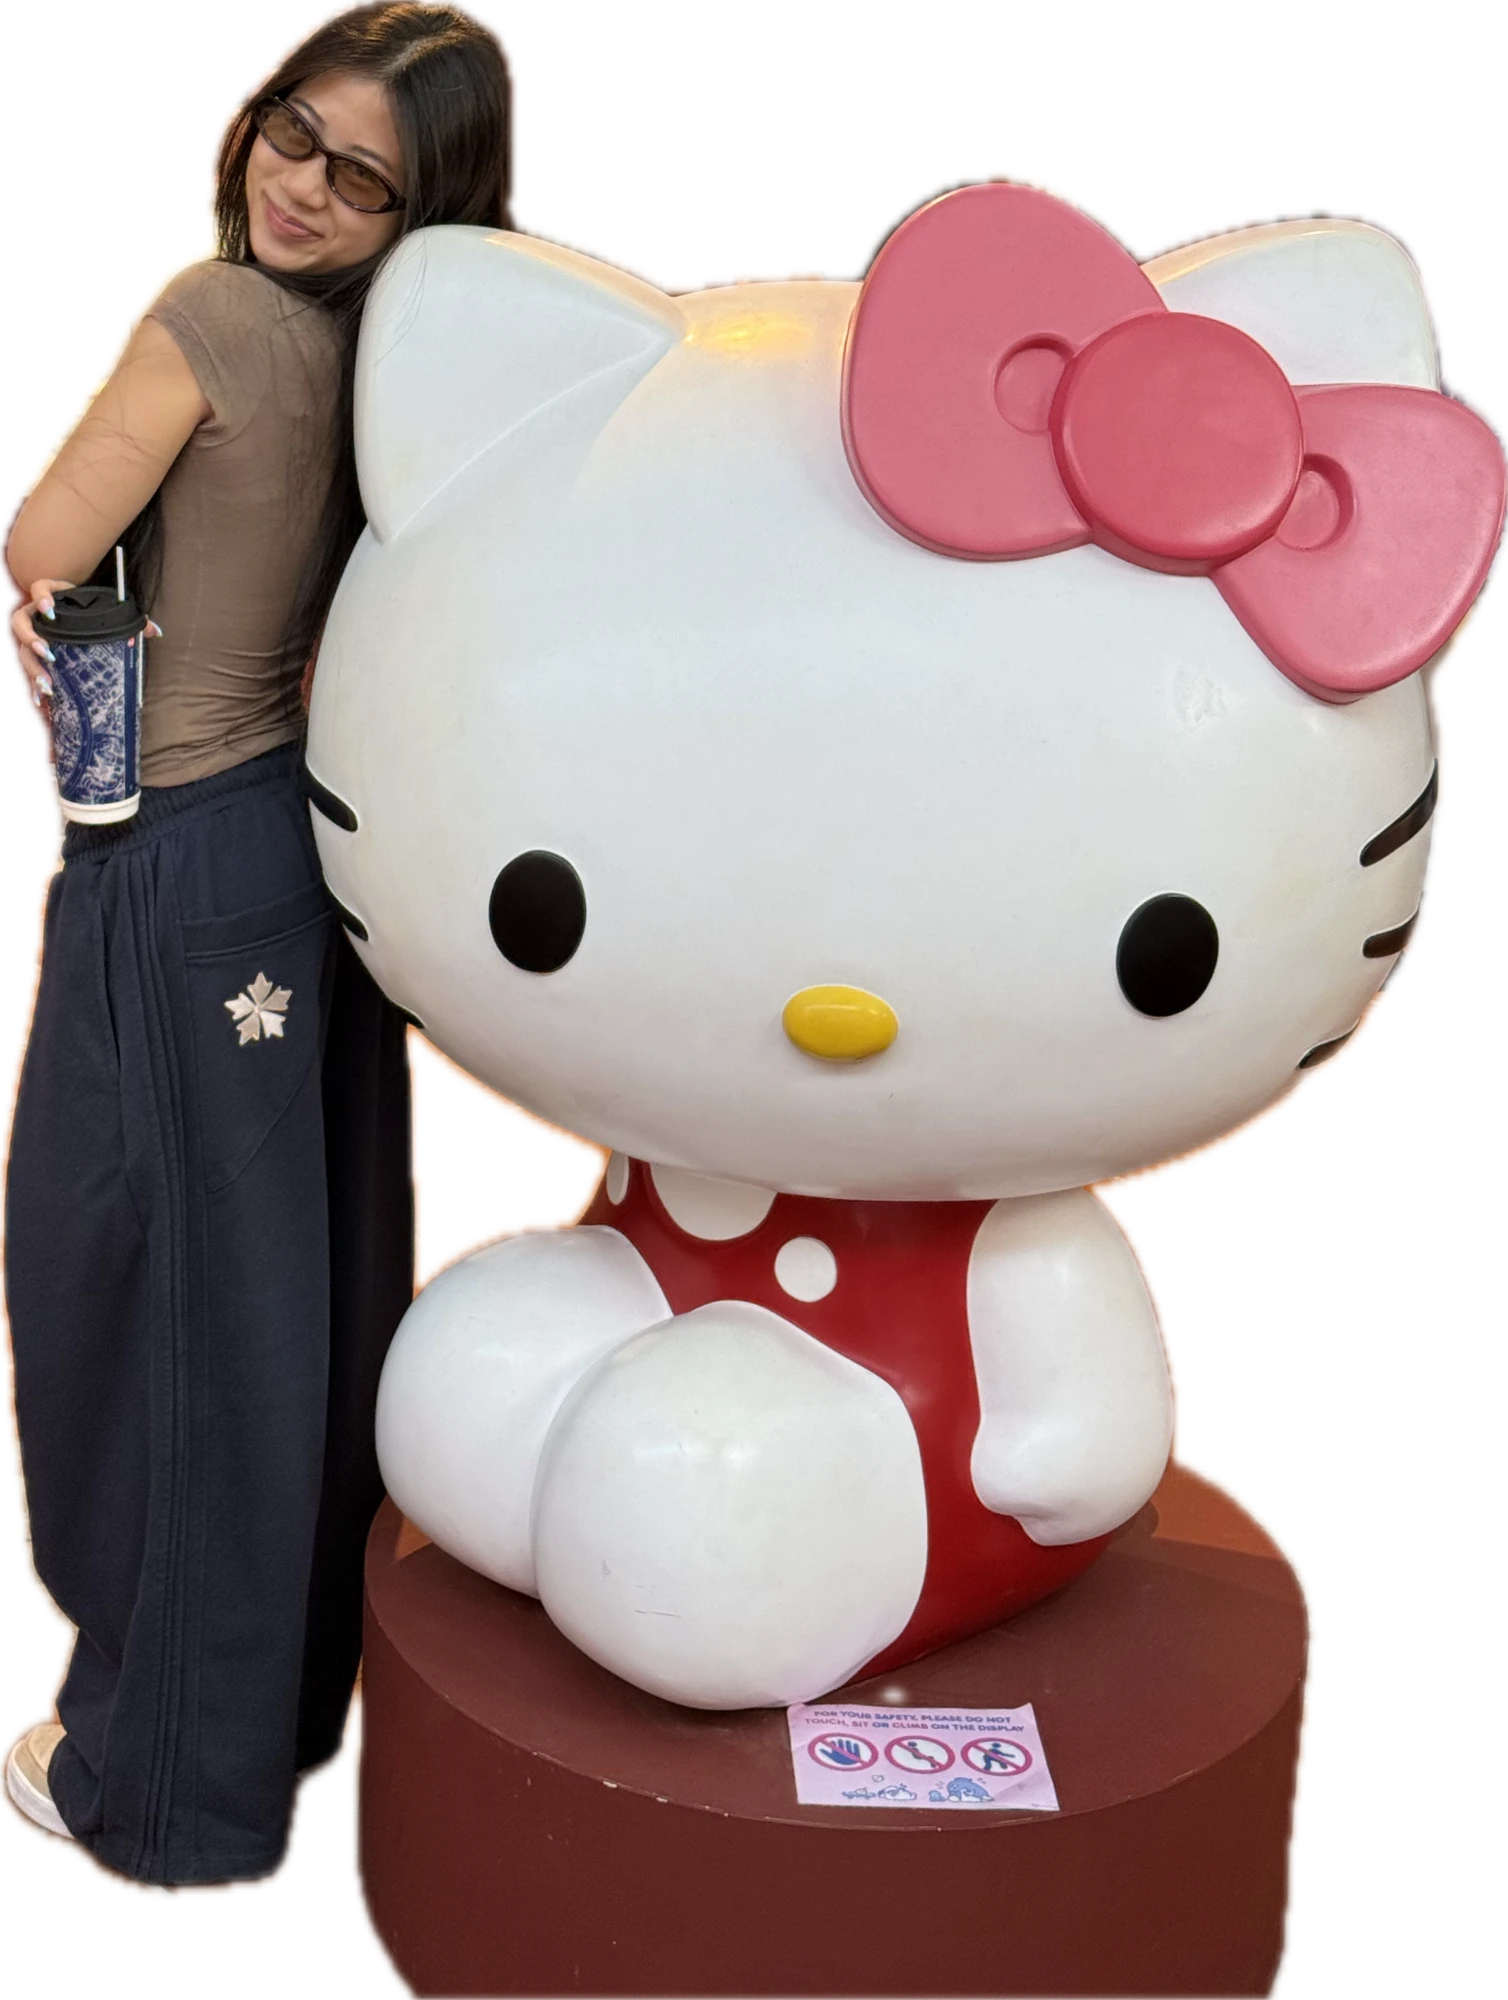
Hi! You can call me Thi, pronounced /tee/. I study Robotics & Machine Intelligence at the National University of Singapore (class of 2029). I spend most of my time on robotics: building things, researching in my lab, and figuring out what I don't understand yet.
This site is where I keep my projects (finished, ongoing, and coming soon) and my notes on what I'm learning and thinking about.
Now
- Dynamic obstacle avoidance and SLAM — Mapping an unknown space while avoiding moving obstacles.
- UROP: UMI and iPhUMI — Undergraduate research on UMI-style handheld data collection for robot learning.
Highlights
see allAutonomous Duster — Arduino UNO
LiDAR Obstacle Reactive Avoidance — ROS
A* Path Planning & PID control — ROS